Co-founder
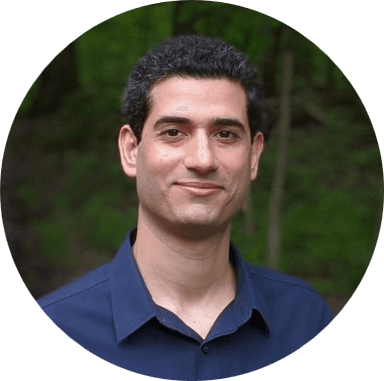
Dr. Maani Ghaffari
Robotics professor at the University of Michigan. Expert in SLAM, autonomy, and system architecture.
GeoMind Robotics
GeoMind is a deep-tech robotics company building geometric world models for reliable autonomy, with expertise across perception, navigation, control, and path planning. We're starting where it's hardest: places GPS can't reach.
Map · building
01Approach
The problem
Robots that shine in demos break down in the field. Bigger perception models alone haven't produced reliable behavior over long horizons, because robots still don't grasp physics, time, and the consequences of their actions.
Our approach
An end-to-end geometric world model: a compact neural representation of the robot and its environment that stays physically consistent over long horizons.
Why it matters
A world model that respects physics lets a robot simulate, plan, and act with confidence. It improves with more data and carries over to situations it hasn't seen, turning fragile prototypes into dependable deployments.
02First product
Autonomy starts with knowing where you are. Our navigation system gives robots a precise, reliable position estimate wherever satellite navigation can't reach.
01
Sensor fusion that actively removes error, keeping a precise position estimate when satellite signals are unavailable, degraded, or jammed.
02
Localization on par with an inertial navigation system, from off-the-shelf sensors, running on a single CPU core.
03
Tracking comparable to or better than equipment costing around ten times as much, lowering the cost of every robot.
Built for
03Traction
Transferring our GPS-free localization technology to autonomous boats, benchmarked against a conventional inertial navigation system.
Counterfactual simulation and explainability for end-to-end autonomous driving.
Active discussions with potential customers in water management and hydrogen mining.
04Founders
Co-founder
Robotics professor at the University of Michigan. Expert in SLAM, autonomy, and system architecture.
Co-founder
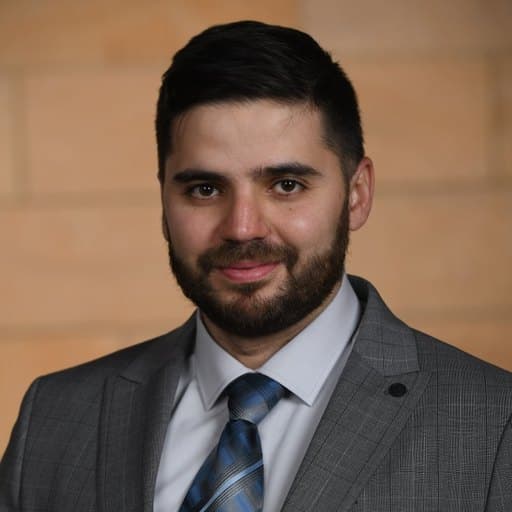
Led Honda Marine research. 17+ years in mobility and systems. MBA from Michigan Ross.
05What's next
Navigation is the foundation. Each product builds on the last, toward a complete end-to-end autonomy stack.
Now
Highly accurate, error-removing sensor fusion. Our current focus.
Future
Control that stays robust to disturbances, with fast compute.
Future
A new method that connects pixels directly to actuators for extremely fast reactions.
Vision
A geometric world model that lets robots simulate, plan, and act with physical consistency.
06Contact
We offer engineering consulting and licensed software to robotics companies, and partner with robot and sensor manufacturers. Tell us what you're working on.